Place a seed
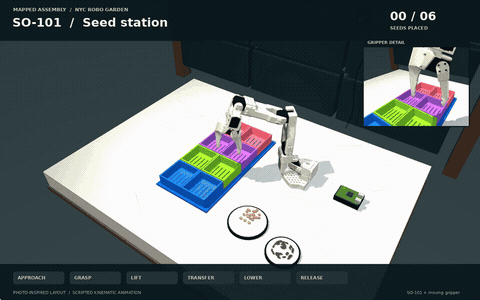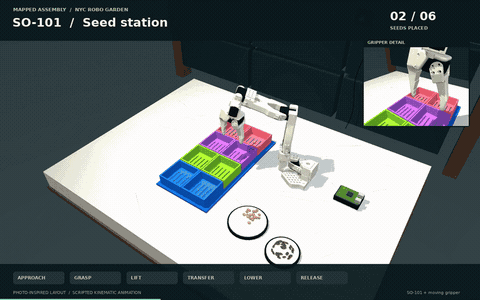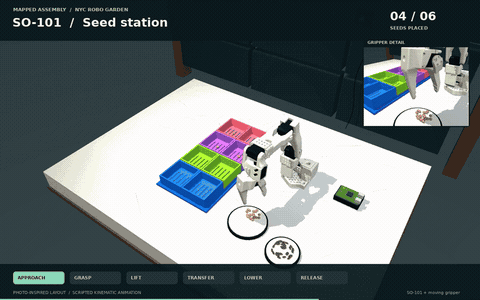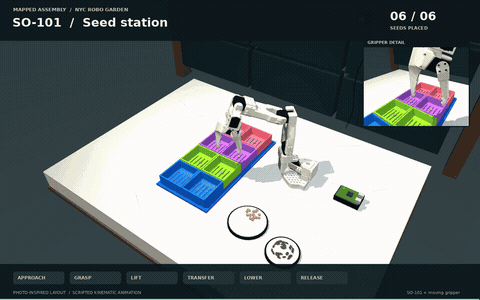
An SO-101 arm, camera tooling, and a seed-tray workflow. The initial research question is reliable placement with little supervision.
INITIAL PHYSICAL TASKCOMMUNITY AGRICULTURE × OPEN ROBOTICS
Practical robotics for the people growing food in our neighborhoods. Starting with one repetitive task: placing seeds into seedling trays.
Built at the Spooky Civic AI Hackathon · NYC, October 2026
01 / START WITH THE GROWER
During the hackathon, Judith “Judi” Desire, founder and executive director of Uptown & Boogie Healthy Project, described how manually sowing individual seedling-tray cells can take hours.
That conversation shaped our first task. We’re exploring a configurable robotic workstation that can locate seeds, place them into tray cells, check the result, and recover from misses.
The goal is to free time for growing and community work—and make the same equipment a hands-on way to learn robotics and AI.
Meet Uptown & Boogie Healthy Project ↗02 / WHAT WE’RE BUILDING
Start with a bounded task. Make execution observable. Test what actually works.
An SO-101 arm, camera tooling, and a seed-tray workflow. The initial research question is reliable placement with little supervision.
INITIAL PHYSICAL TASKScripted seed handling and a quadruped carrying a mounted arm let us explore motion, viewpoints, and garden tasks.
WORKING VISUALIZATIONSTest correctly seeded cells, misses, doubles, seed damage, operator time, and total cost against manual work and a tray seeder.
VALIDATION AHEADWhere the prototype stands. Simulation, scene-authoring, camera, and connection tools exist. Reliable autonomous seed placement, field navigation, and labor savings have not yet been demonstrated. Read the evidence and limitations ↗
03 / ROOTED IN NEW YORK CITY
Explore public garden records across all five boroughs. A simple city outline, real location points, and filters to find a place by name or neighborhood.
Open the garden explorer ↗Garden listings are discovery leads, not confirmed food-production sites or approved robot workspaces.
St. Nicholas boundary reference ↗04 / BUILD, LEARN, SHARE
Our longer-term vision is affordable, reusable equipment that growers and learners can configure, maintain, and share.
Seed placement provides a tangible learning path: define a task, change a simulation, inspect camera images, calibrate an arm, and measure the outcome. Community workshops and shared equipment are possibilities we want to explore.
Affordability needs evidence, too. A specialized seeder may be the better tool. We’re asking where adaptable robotics can earn its place.
Read the research and cost comparisons ↗OPEN SOURCE / WORK IN PROGRESS